Blog
Articles on how we build simulation environments, and case studies from the customers using them.
Article · September 2026
World models vs. physics simulation
The two ways to build a simulation environment for a robot, where each one shines, and how we choose between them for every task.
Read article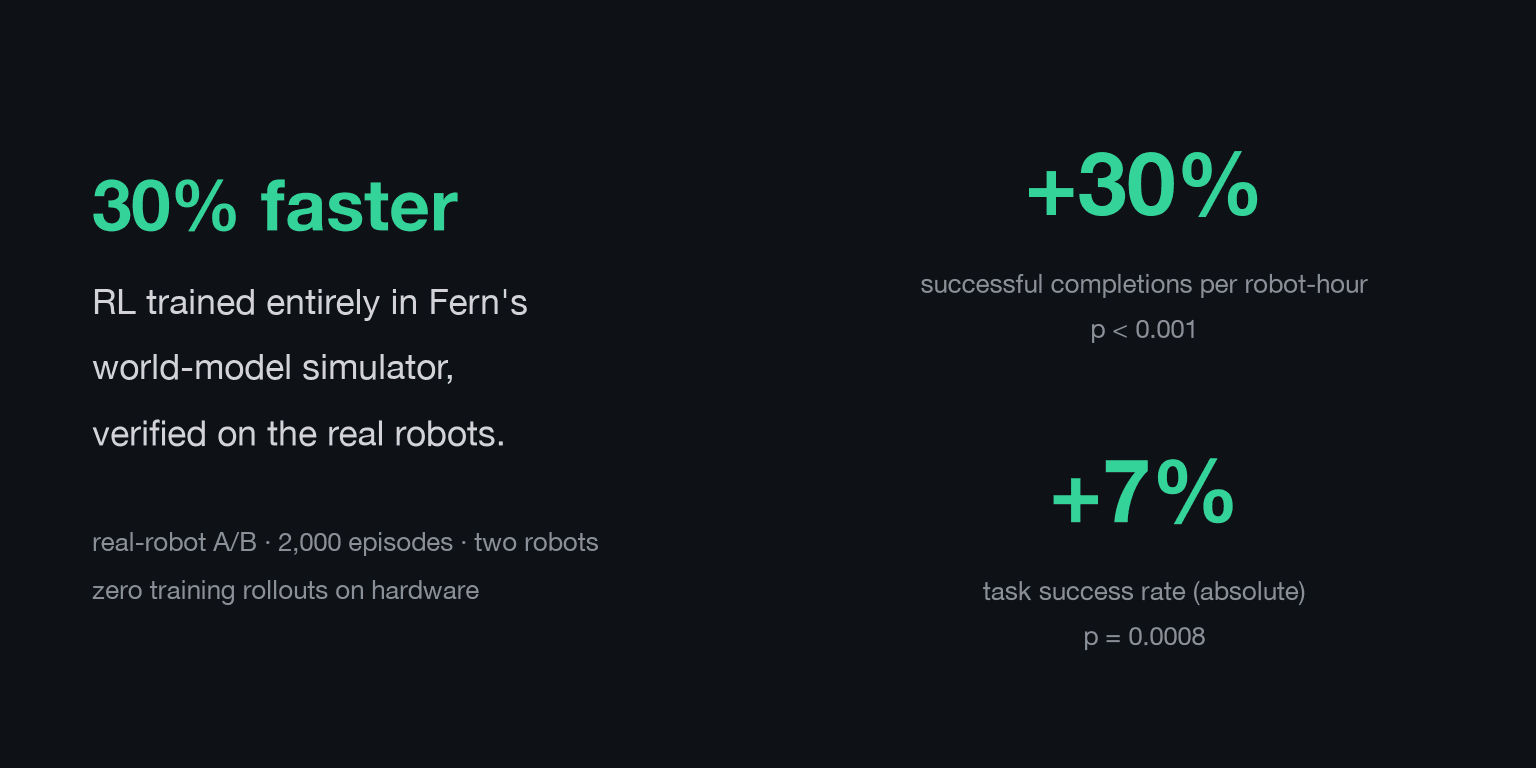
Case study · July 2026
Making robots faster and more successful with RL trained entirely in simulation
We used RL to improve a customer's manipulation policy without a single training rollout on their hardware. All of it happened inside Fern's learned simulator. Deployed on the real robots, it delivered 30% more successful completions per robot-hour (p < 0.001) and a 7% absolute improvement in task success rate (p = 0.0008).
Read case study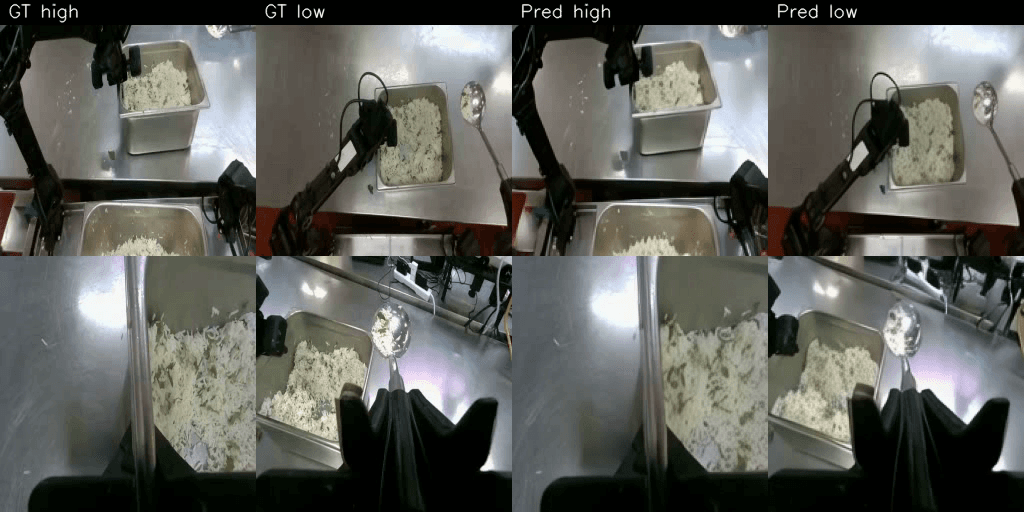
Case study · June 2026
Closing the loop for a vertical robotics company
We ran a customer's rice-scooping policy end-to-end inside Fern's learned simulator. Its joint-level actions tracked the real robot almost exactly: full closed-loop evaluation, not teleop replay.
Read case study